Measurement and Control Engineering – Mechatronics Working Group
Prof. Dr.-Ing. Oliver Nelles
Research Topics: Christopher Illg
Nonlinear Regularized FIR Models
System identification involves estimating dynamic models from finite, noisy measurement data. Additionally, some prior knowledge can be incorporated using simple structural assumptions. This procedure is called gray-box modeling.
The idea proposed in [6] corresponds to a gray-box modeling approach for estimating finite impulse response (FIR) model structures. FIR models have no output feedback, whereas external feedback is what makes ARX models so powerful. However, this comes with some drawbacks for ARX models: biased parameter estimation, an equation-error configuration, and problems with multivariate feedback [2]. On the other hand, parameter estimation for FIR models is unbiased; they have an output-error configuration and are inherently stable. Typically, estimating FIR models requires a large number of parameters, which leads to high error variance. Regularization can be used to address this issue. Prior knowledge can be incorporated by introducing an additional penalty term into the estimation procedure. This regularization term establishes a relationship among the parameters of the FIR model itself.
To easily apply regularized FIR models in the nonlinear domain, local model networks (LMNs) can be used. The output of an LMN is calculated as an interpolation of local models (LMs) with their associated validity functions Φi, i = 1, ..., M [5]. The input to the LMs is spanned by x(k), while the input to the validity functions uses a different space, z(k) (see Figure 1) [3]. The validity functions can be determined using incremental tree-based construction algorithms with axis-orthogonal or axis-oblique partitioning [5].
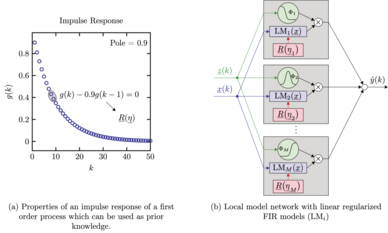
Figure 1: Nonlinear regularized FIR models.
Nonlinear Laguerre and Kautz Models
Nonlinear dynamic models form the basis for most sophisticated methods in areas such as prediction, simulation, optimization, control, fault detection, and diagnosis. The most popular approach in nonlinear system identification is to establish a regressor space with filtered inputs and, optionally, filtered outputs combined into the regressor vector x. The behavior of the nonlinear system itself is then modeled by a universal approximator (NL); see Figure 2.
The choice of the regressor vector x is crucial for modeling the dynamics. On the one hand, the vector can consist of (a) only delayed versions of the input (FIR) or internal filtering of the input using cascades of filters with (b) a real pole (Laguerre) or (c) a complex pole pair (Kautz) [1]. Laguerre and Kautz input spaces allow for a significantly reduced dimensionality of the regressor space compared to the FIR regressor space, since lower model orders can capture the significant process dynamics. The pole(s) p is a hyperparameter and can be optimized or chosen heuristically. On the other hand, (d) a combination of delayed versions of the input and output (ARX) is also possible, in which case external feedback is used.
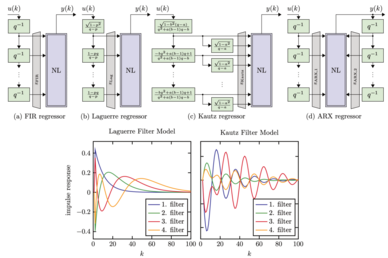
Figure 2: Different regressor spaces that depend only on filtered/delayed versions of the input (FIR, Laguerre, Kautz) and one that uses external feedback (ARX) with xARX = [xARX,1,xARX,2]. The NL block represents the universal approximator, which models the static nonlinearity.
Model Predictive Control with Local Model Networks
The main task in model predictive control (MPC) is to predict the future output of the process and estimate an optimal sequence for the manipulated variable with respect to an objective function. To control nonlinear processes using MPC, the nonlinear process model is often first linearized, and the linearized model is then used to predict the next time steps. The advantage of a linear model in MPC is that it provides a closed-form solution, which is computationally efficient and yields a global optimum.
For the internal model, a local model network (LMN) with regularized finite impulse response (FIR) models can be selected. The linear model at the current operating point can be easily calculated by interpolating the model parameters of all local models. Regularized FIR models are well-suited for online identification because they are inherently stable. Further advantages include, for example, the linearity of the parameters, the output error configuration, and insensitivity to incorrect model order or incorrect dead times. Additionally, regularization improves the robustness of the closed-loop online identification procedure [4]. For the online system identification of the local models of the LMN, a recursive weighted least squares (RWLS) method can be applied. A block diagram of an adaptive MPC is shown in Figure 3.
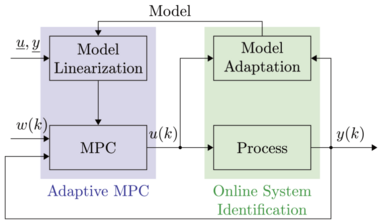
Figure 3: Adaptive model predictive control with online system identification.
References
| [1] | Paul M.J. Van den Hof, Peter S. C. Heuberger, and J. Bokor. “System Identification with Generalized Orthonormal Basis Functions.” In: Proceedings of the 1994 33rd IEEE Conference on Decision and Control. IEEE, 1994. |
| [2] | Christopher Illg, Tarek Kösters, and Oliver Nelles. “Handling of Time Delays in MISO Processes with Regularized Finite Impulse Response Models.” In: 2024 European Control Conference (ECC). 2024, pp. 3545–3550. |
| [3] | Christopher Illg, Tarek Kösters, and Oliver Nelles. “On the Choice of the Scheduling Variables for Dynamic Local Model Networks with Local Regularized FIR Models.” In: 2024 IEEE International Conference on Fuzzy Systems (FUZZ-IEEE). 2024, pp. 1–8. |
| [4] | Christopher Illg and Oliver Nelles. “Adaptive Model Predictive Control with Regularized Finite Impulse Response Models.” In: ATHENA Research Book, Volume 1, No. 1 (2022), pp. 327–331. |
| [5] | Oliver Nelles. Nonlinear System Identification: From Classical Approaches to Neural Networks, Fuzzy Systems, and Gaussian Processes. 2nd ed. Springer International Publishing AG, 2021. |
| [6] | Gianluigi Pillonetto and Giuseppe De Nicolao. “A New Kernel-based Approach for Linear System Identification.” In: Automatica 46.1 (Jan. 2010), pp. 81–93. |